Offworld Builder
A game that trains the robots that will build on the Moon.
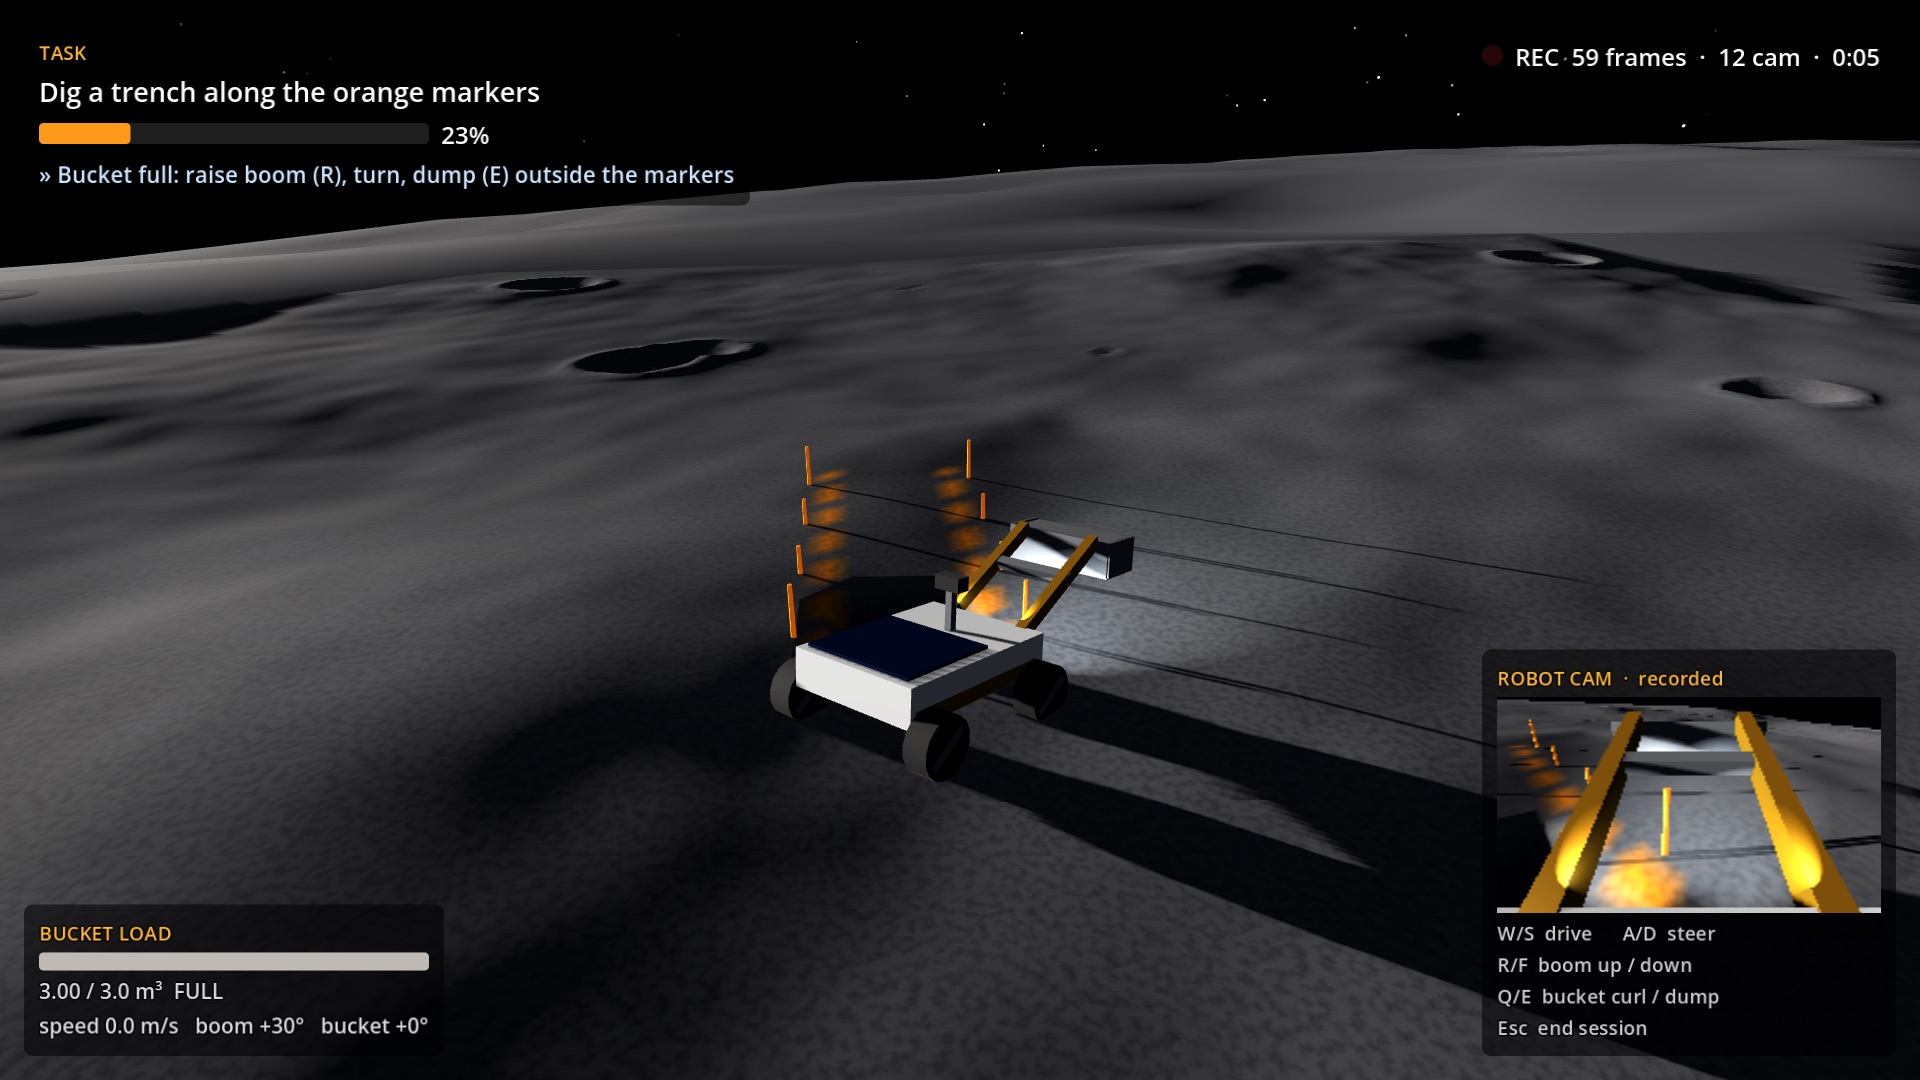
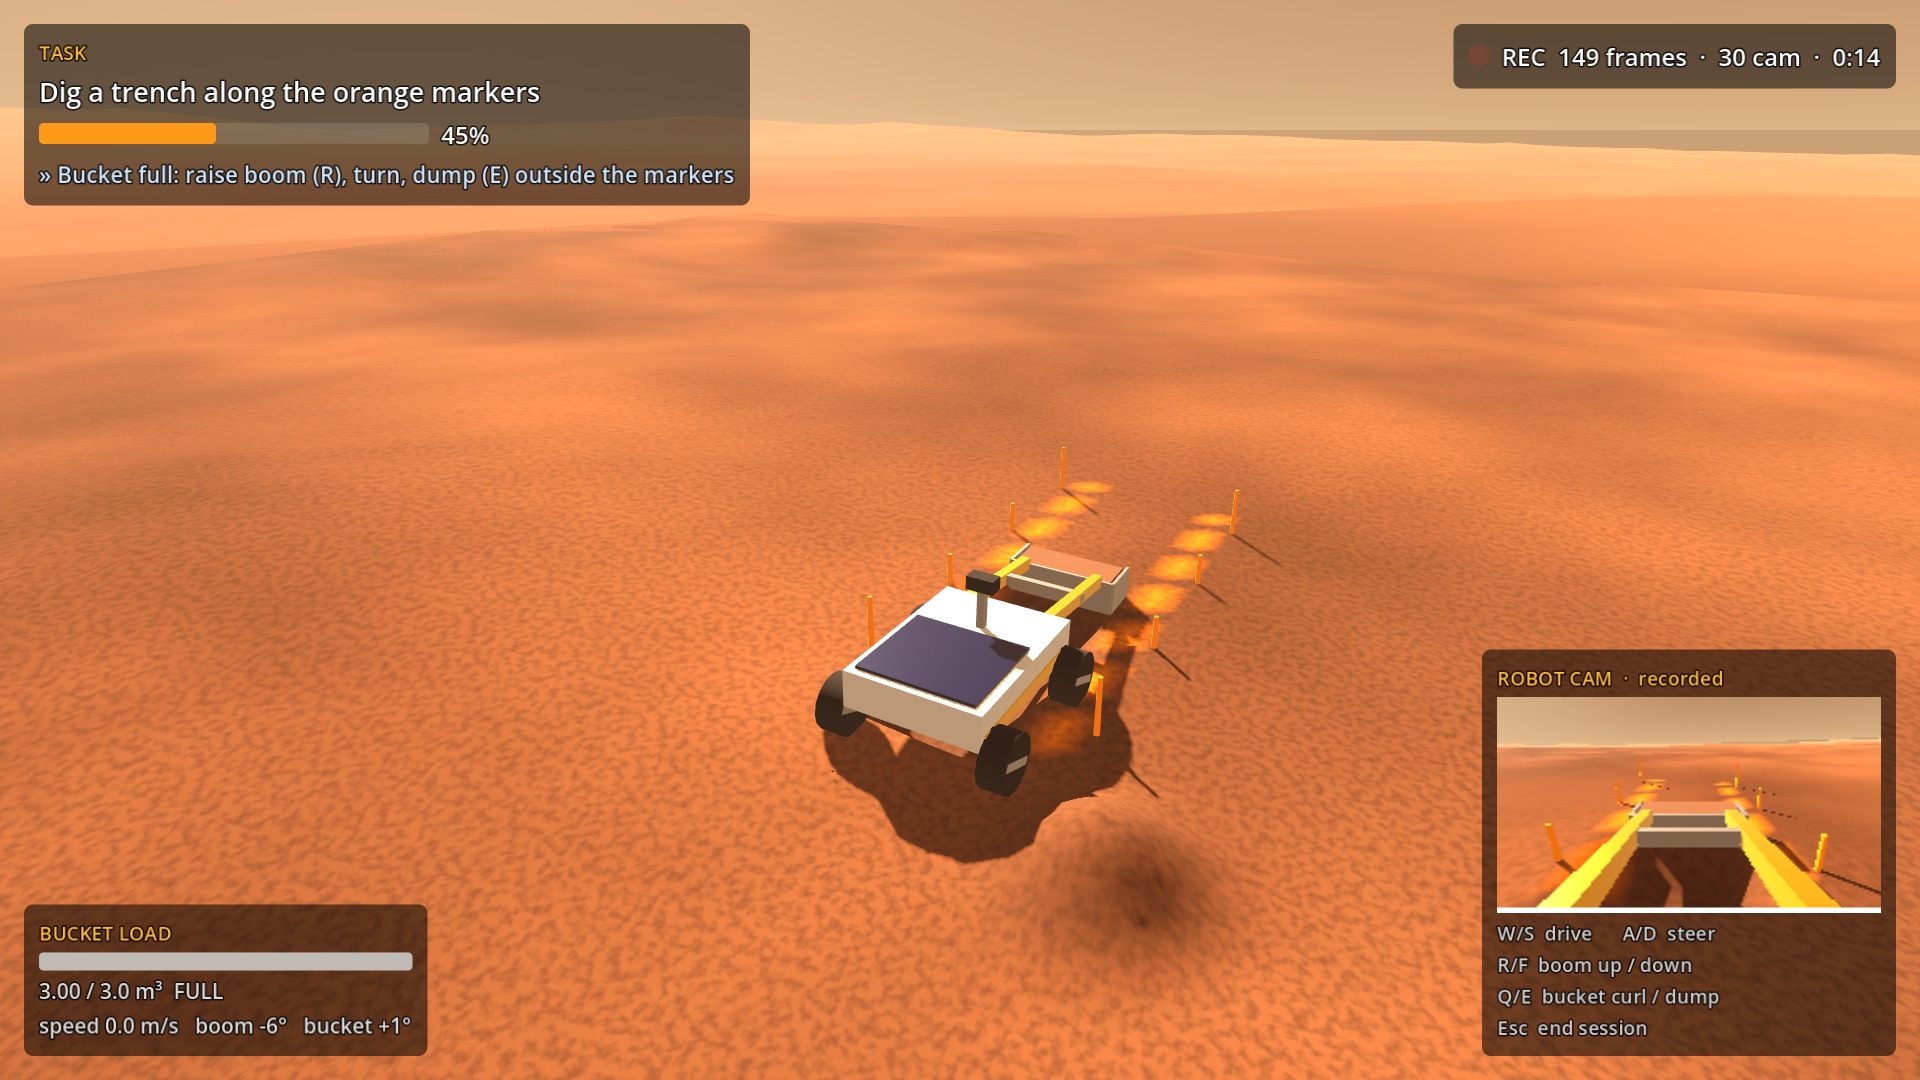
Players run an excavator on real lunar and Martian terrain, free in the browser. Every session is logged as robot training data: what the machine observed, paired with exactly what the controller did.
What's in it
Grounded where it can be, labelled where it isn't.
Real terrain
The Moon is a 2 m NASA LROC NAC elevation model of Connecting Ridge at the lunar south pole, with the sun 3° above the horizon. Mars is a 1 m HiRISE model of the Jezero landing site. Each world uses its own gravity.
Soil physics
Cutting forces from the McKyes/Reece earthmoving equation, the drag of soil held in the bucket, a bearing-capacity limit on how far the bucket can be pushed in, and Bekker wheel–soil models for sinkage and slip. Lunar values come from the Lunar Sourcebook; Mars values are approximated.
Real jobs
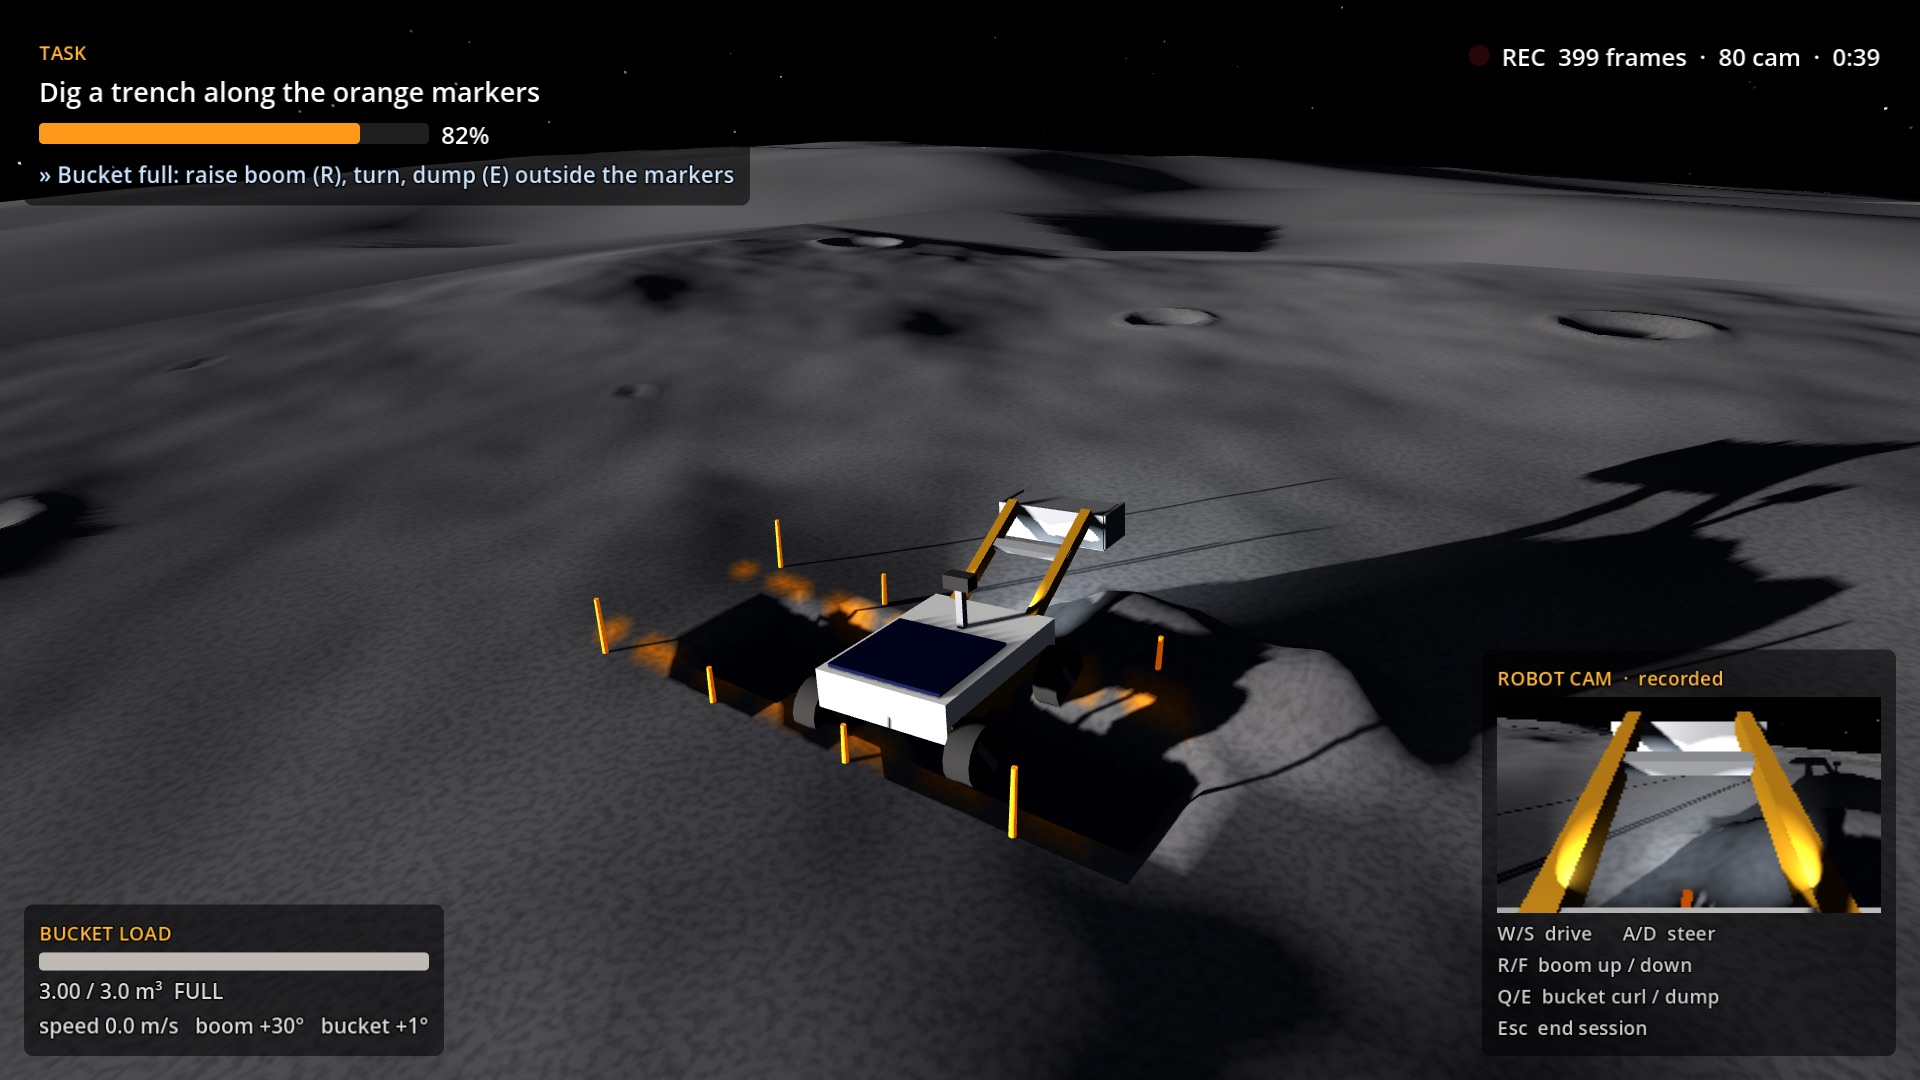
Dig an 8 m trench along a surveyed line, or level an 8 × 8 m landing pad to within 5 cm. Construction jobs that lunar missions will need, scored the way a site engineer would.
Signal delay
Drive directly, by delayed teleoperation (1.3 s each way on the Moon), or by supervised autonomy: place dig and dump zones and waypoints, send the plan, and watch the machine carry it out. Supervised autonomy is the default on Mars.
The simulation fidelity page lists what is grounded in real data, what is approximated, and what is still on the roadmap, with sources.
The data
Every session is a demonstration.
The game logs the machine's state, the terrain around it, soil forces and the controls at 10 Hz, with a robot-camera image at 2 Hz. Each session records who was in control (a person, a scripted controller or a learned policy), which world, which terrain source, which control mode and which lighting. Labels are never mixed.